HapticVLA: New Model for Handling Fragile Objects with Care
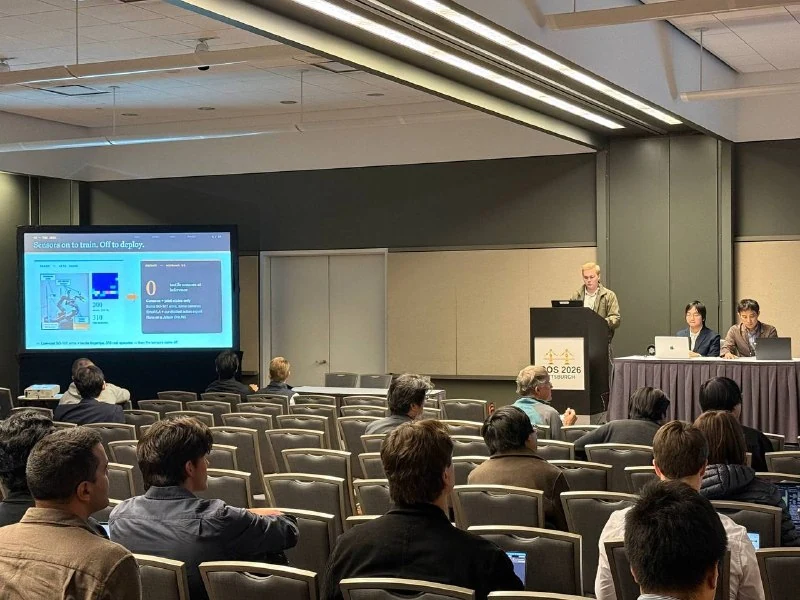
Researchers introduced HapticVLA, a Vision-Language-Action model trained to handle fragile items like eggs and waffles, using tactile sensors only during training.
HapticVLA: New Model for Handling Fragile Objects with Care
Researchers have introduced HapticVLA, a Vision-Language-Action (VLA) model trained to carefully manipulate fragile objects such as eggs, waffles, and jars of marmalade.
Key Innovation
The standout feature of this approach is that tactile sensors are required only during the training phase. The physical robot operating in the real world does not have any touch sensors at all. This significantly simplifies the hardware requirements while maintaining high manipulation skills.
This case highlights current trends in robotics, where the focus is shifting towards efficient training methods and simulation-to-real transfer.
Why it matters
AnalysisIt demonstrates how tactile sensitivity skills can be transferred to systems without expensive sensors, reducing robot cost and complexity.
Discuss in community
Share your questions and insights with developers
Related in Ecosystem
Practical guides, core terminology, and agent skills
JSON — Structured Data for Programs, APIs, and AI Agents
A complete hands-on guide to JSON: syntax specifications, serialization via parse and stringify, REST API consumption, JSON Schema validation, and structured outputs for LLMs.
DOCX and XLSX Formats: When AI Needs to Deliver Production-Ready Documents
A comprehensive hands-on guide to generating and processing DOCX documents and XLSX workbooks with AI: comparing against Markdown and CSV, prompt engineering, formula design, and code automation.
Anthropic Publishes Guide to Building Always-On AI Agents
Anthropic has released a new guide covering the core mechanisms behind continuously active AI agents, including event handling, timers, memory, and task continuity.
Freefield: Run a Free Higgsfield-Style AI Studio for Images, Video, and Audio on Your PC
Freefield brings 117 AI tools for creating and editing images, video, and audio to a local PC, using open models such as FLUX 3, LTX-2.5, and Wan without subscriptions or paid APIs.